Inspect the design
Run the pan and tilt sweep and open the camera preview.
Lookout is an anchored camera rig with independent pan and tilt commands, a control board and a virtual compute host. Plan an observation platform and watch the rendered camera view change with its kinematic motion.
Includes assembly, starter wiring and executable virtual JavaScript.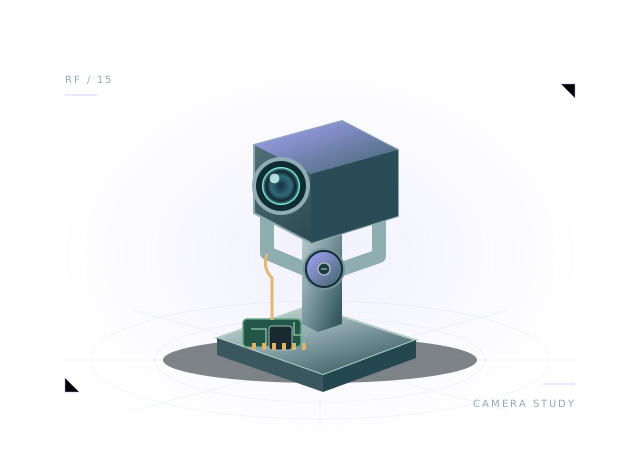 Concept illustration · inspect actual geometry above.
An anchored pan/tilt-style camera, power and control assembly. All 9 components and 15 starter connections remain editable in your own project.
Use the starting assembly to ask better questions about your design. Save a copy, change a parameter and compare what happens.
Run the pan and tilt sweep and open the camera preview.
Inspect the camera's data connection and the two servo PWM channels.
Use a rendered observation with a supported AI adapter to prototype a visual interaction.
function step(robot) {
  robot.drive(0, 0);
  if (robot.brownout || robot.battery.voltage < 6.25) { robot.display('🪫'); return; }
  robot.servo('pan', 0.55 * Math.sin(robot.time * 0.6));
  robot.servo('tilt', 0.16 * Math.sin(robot.time * 0.9));
}
The full, editable starter script is included in the workbench.
Working pan/tilt kinematic sweep moves the camera and rendered observations. Collision shapes and inertia remain at their reference pose.
This is a virtual JavaScript environment. It does not emulate ESP-IDF, Arduino firmware or a manufacturer's exact hardware.
A two-wheel teaching robot with a downward sensor layout.
Compact face, display and expressive servo with 3.3 V GPIO aliases.
Open the template, inspect the wiring and run its first behavior.