Inspect the design
Run the eight-servo in-place cycle and follow each named leg joint.
Paw lays out eight servos around a central power and control body. Its in-place leg cycle makes a larger assembly easier to understand while you work through naming, grouping, wiring and independent servo commands.
Includes assembly, starter wiring and executable virtual JavaScript.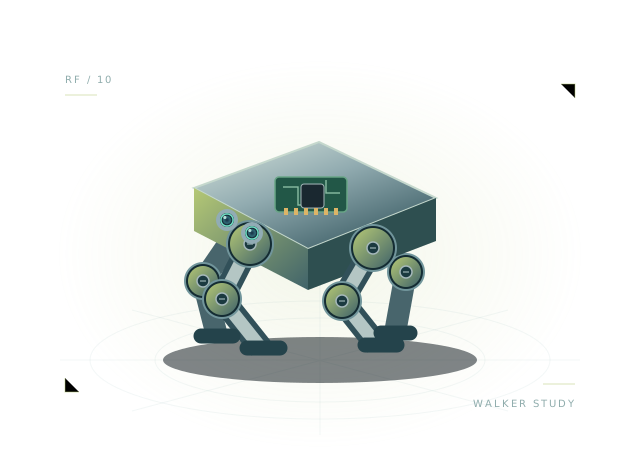 Concept illustration · inspect actual geometry above.
Four legs, eight servo positions and a central power/control body. All 24 components and 28 starter connections remain editable in your own project.
Use the starting assembly to ask better questions about your design. Save a copy, change a parameter and compare what happens.
Run the eight-servo in-place cycle and follow each named leg joint.
Isolate a leg group to inspect its upper link, knee, lower link and foot.
Trace the common power rails and independent control channels for all eight servos.
const legs = ["rear-left","rear-right","front-left","front-right"];
function step(robot) {
  robot.drive(0, 0);
  if (robot.brownout || robot.battery.voltage < 6.25) { robot.display('🪫'); return; }
  legs.forEach((leg, i) => {
    const phase = robot.time * 2 + (i === 0 || i === 3 ? 0 : 1) * Math.PI;
    robot.servo('leg-' + leg + '-hip', 0.14 * Math.sin(phase));
    robot.servo('leg-' + leg + '-knee', 0.10 * (1 - Math.cos(phase)));
  });
  robot.display('😊');
}
The full, editable starter script is included in the workbench.
Eight independent servo commands animate an in-place leg cycle. Contact shapes remain at the reference pose; no dynamic gait, locomotion, balance or footfall solver.
This is a virtual JavaScript environment. It does not emulate ESP-IDF, Arduino firmware or a manufacturer's exact hardware.
Compact face, display and expressive servo with 3.3 V GPIO aliases.
Open the template, inspect the wiring and run its first behavior.