Inspect the design
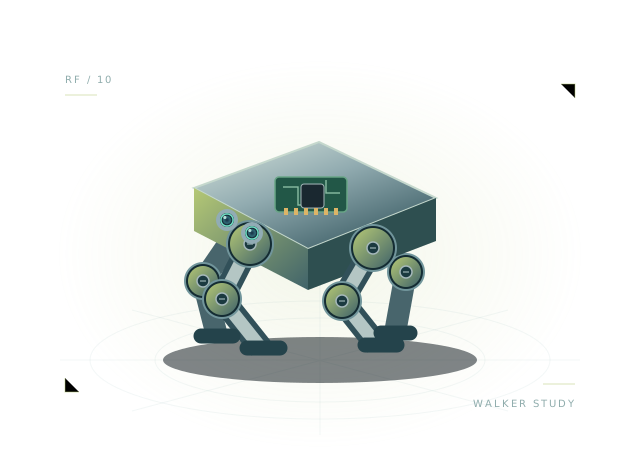
Inspect the two leg chains and the torso-mounted display.
Stride combines a torso, broad support feet and four servo positions in a biped layout. Use its in-place motion preview to study how the pieces relate, and build familiarity with independently controlled joints.
Includes assembly, starter wiring and executable virtual JavaScript.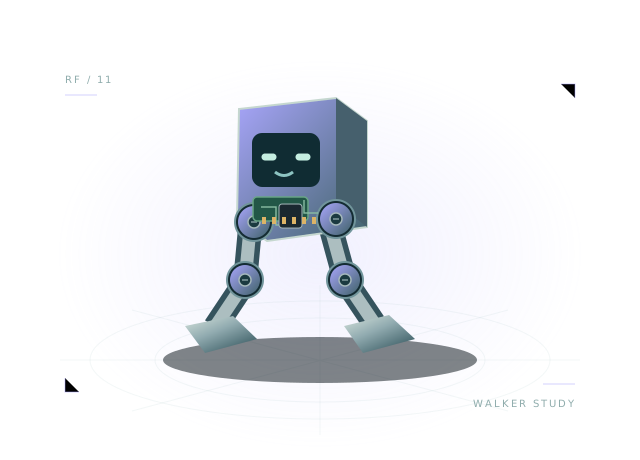 Concept illustration · inspect actual geometry above.
Two legs and broad feet for support, assembly and wiring studies. All 15 components and 20 starter connections remain editable in your own project.
Use the starting assembly to ask better questions about your design. Save a copy, change a parameter and compare what happens.
Inspect the two leg chains and the torso-mounted display.
Run the four-joint in-place cycle and change its phase or amplitude.
Compare the broad support feet and reference assembly while planning a physical prototype.
const legs = ["front-left","front-right"];
function step(robot) {
  robot.drive(0, 0);
  if (robot.brownout || robot.battery.voltage < 6.25) { robot.display('🪫'); return; }
  legs.forEach((leg, i) => {
    const phase = robot.time * 2 + i * Math.PI;
    robot.servo('leg-' + leg + '-hip', 0.14 * Math.sin(phase));
    robot.servo('leg-' + leg + '-knee', 0.10 * (1 - Math.cos(phase)));
  });
  robot.display('😊');
}
The full, editable starter script is included in the workbench.
Four servo commands animate an in-place leg cycle. Contact shapes remain at the reference pose; no walking locomotion or self-balancing dynamics.
This is a virtual JavaScript environment. It does not emulate ESP-IDF, Arduino firmware or a manufacturer's exact hardware.
Compact face, display and expressive servo with 3.3 V GPIO aliases.
Open the template, inspect the wiring and run its first behavior.