Inspect the design
Compare the turret, camera and host arrangement with the compact vacuum.
Sweep Pro adds a LiDAR turret and a camera host to the vacuum concept. Study a more instrumented household robot while keeping a clear distinction between supported range and camera behavior and illustrative hardware.
Includes assembly, starter wiring and executable virtual JavaScript.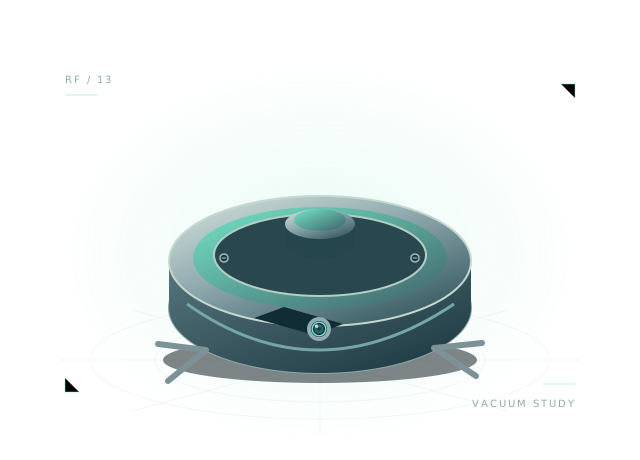 Concept illustration · inspect actual geometry above.
A vacuum layout with a LiDAR turret and camera host. All 22 components and 45 starter connections remain editable in your own project.
Use the starting assembly to ask better questions about your design. Save a copy, change a parameter and compare what happens.
Compare the turret, camera and host arrangement with the compact vacuum.
Try rendered camera observations alongside the working range avoidance demo.
Inspect the sensor power routes and assembly mass before choosing physical parts.
function step(robot) {
  robot.drive(0, 0);
  if (robot.brownout || robot.battery.voltage < 6.25) { robot.display('🪫'); return; }
  const range = robot.sensors.range;
  if (!Number.isFinite(range)) { robot.display('⚠️'); return; }
  const obstacle = range < 0.65;
  robot.drive(obstacle ? -0.3 : 0.45, obstacle ? 0.35 : 0.45);
  robot.display(obstacle ? '🤔' : '😊');
}
The full, editable starter script is included in the workbench.
Range-based avoidance and camera observations run. LiDAR is a layout part; SLAM, room coverage and dust pickup are not implemented.
This is a virtual JavaScript environment. It does not emulate ESP-IDF, Arduino firmware or a manufacturer's exact hardware.
Round chassis, two drive wheels, a brush layout and range sensing.
Compact face, display and expressive servo with 3.3 V GPIO aliases.
Open the template, inspect the wiring and run its first behavior.