Inspect the design
Run the shoulder and elbow sweep and inspect how child links follow their joints.
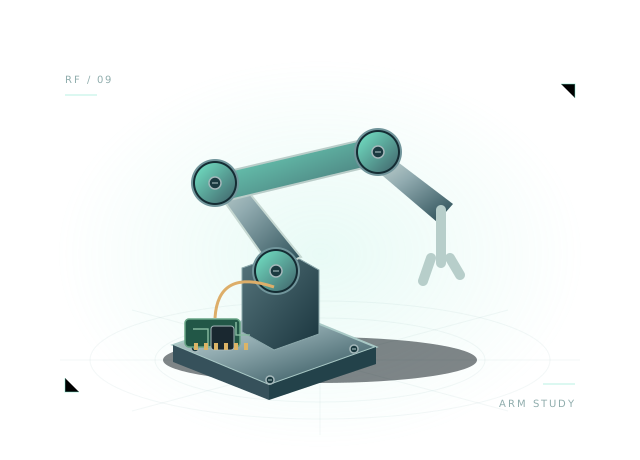
Reach is an anchored desktop arm with two servo locations, two links and a gripper layout. Use its moving kinematic preview to understand the assembly hierarchy and plan control and power before a physical build.
Includes assembly, starter wiring and executable virtual JavaScript.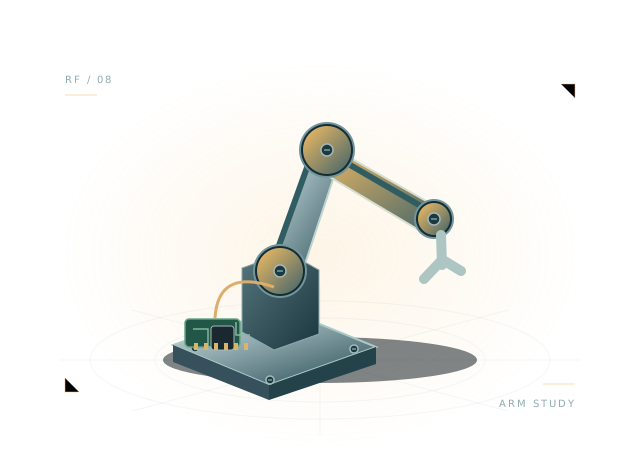 Concept illustration · inspect actual geometry above.
Two servo locations, two links, a gripper and an anchored base. All 10 components and 10 starter connections remain editable in your own project.
Use the starting assembly to ask better questions about your design. Save a copy, change a parameter and compare what happens.
Run the shoulder and elbow sweep and inspect how child links follow their joints.
Edit named servo targets in the included JavaScript example.
Compare link mass and reference-pose gravity moment estimates when changing parts.
function step(robot) {
  robot.drive(0, 0);
  if (robot.brownout || robot.battery.voltage < 6.25) { robot.display('🪫'); return; }
  robot.servo('shoulder', 0.28 + 0.16 * Math.sin(robot.time * 0.8));
  robot.servo('elbow', -0.22 + 0.14 * Math.sin(robot.time + 0.8));
  robot.display('🤖');
}
The full, editable starter script is included in the workbench.
Working two-joint kinematic sweep with moving links. Static load estimates remain at the reference pose; no solved joint torque, moving-link collisions, IK or grasping.
This is a virtual JavaScript environment. It does not emulate ESP-IDF, Arduino firmware or a manufacturer's exact hardware.
Compact face, display and expressive servo with 3.3 V GPIO aliases.
Open the template, inspect the wiring and run its first behavior.